FISS Planner
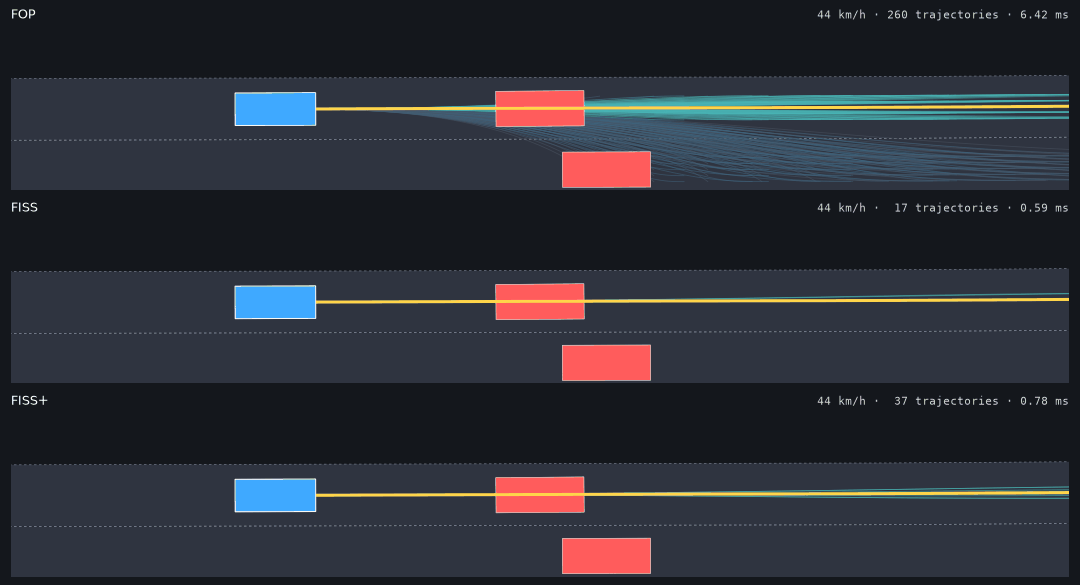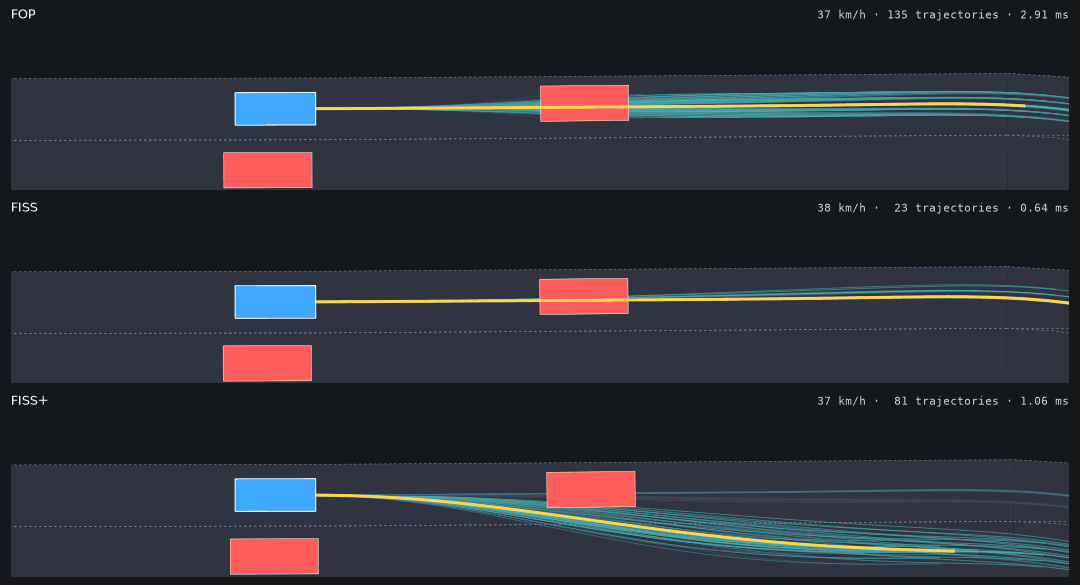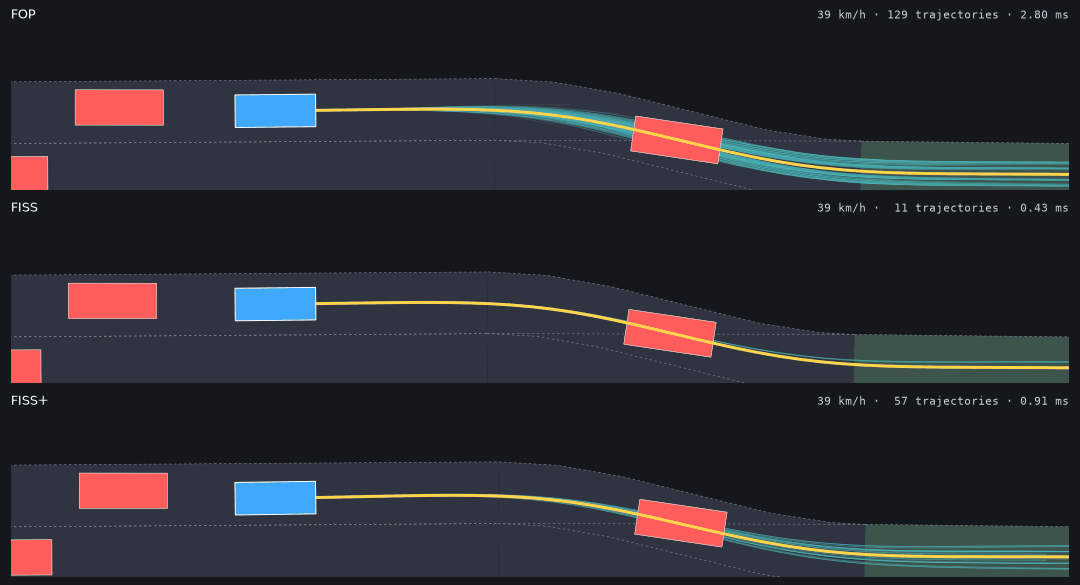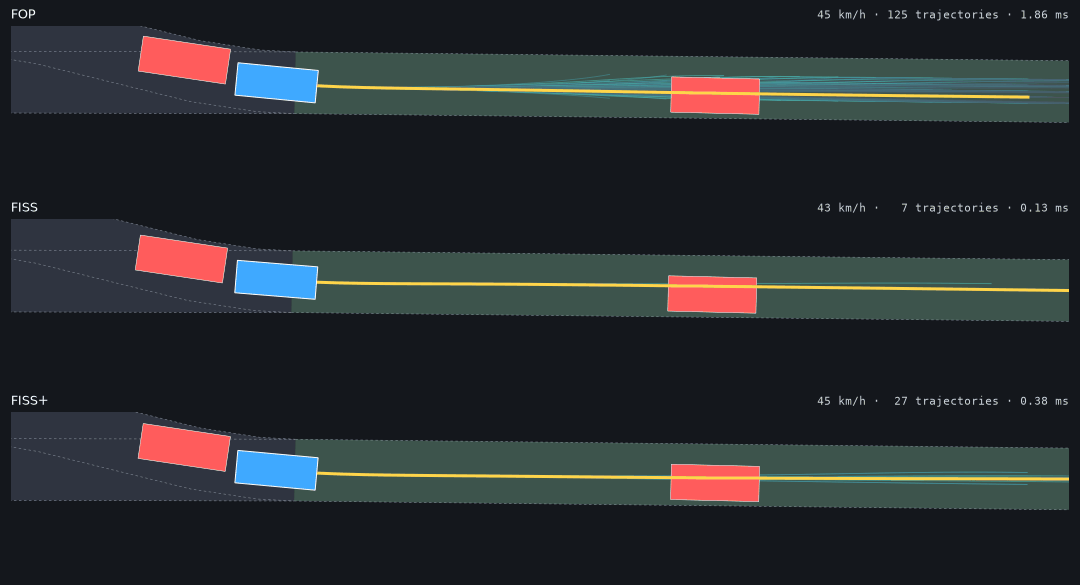
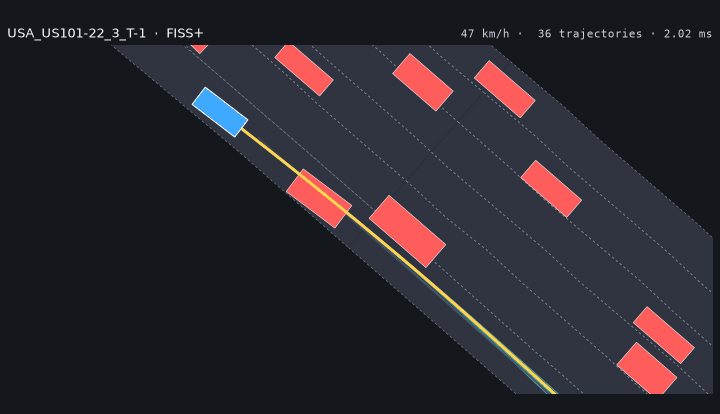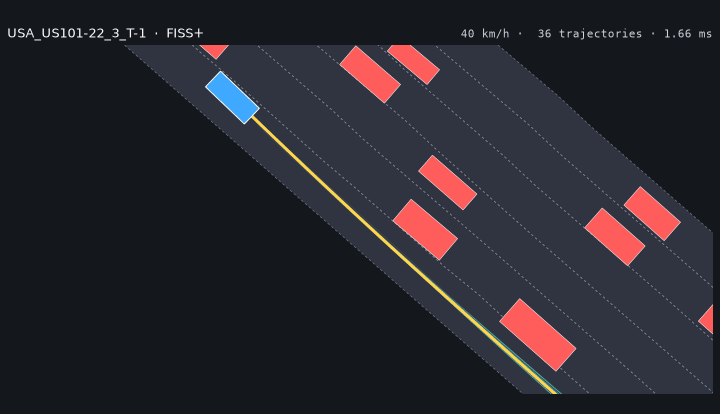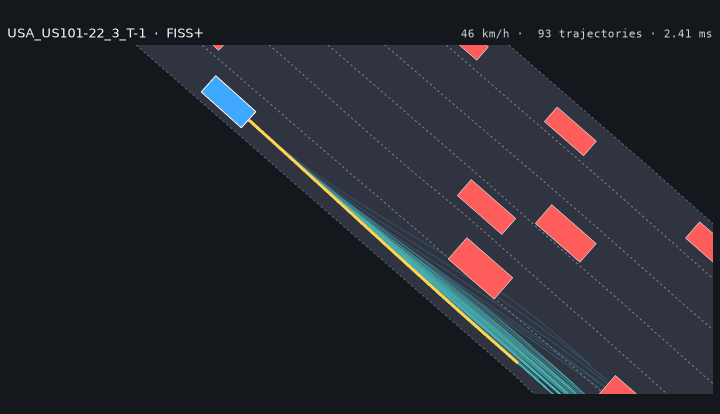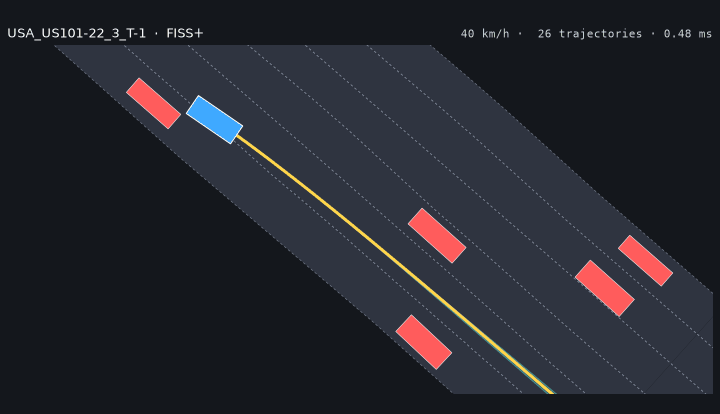
Fast Iterative Search and Sampling trajectory planners for autonomous driving: FISS (RA-L 2022) and FISS+ (IROS 2023), with the FOP and FOP+ baselines, in one C++17 core with Python bindings and ROS 1 / ROS 2 nodes, Lanelet2 / CommonRoad / CARLA support, an optional QP smoother and an MPC controller.
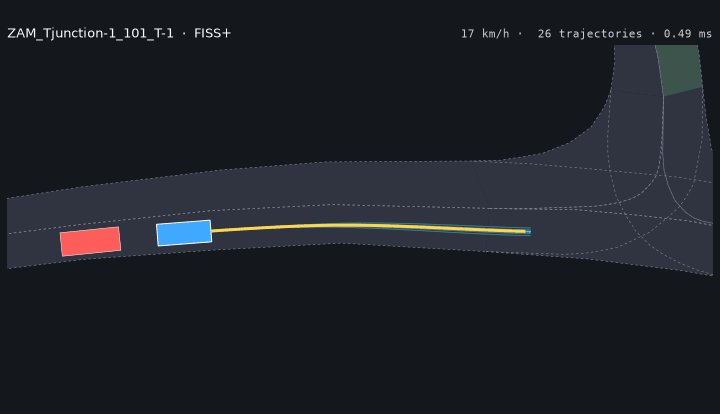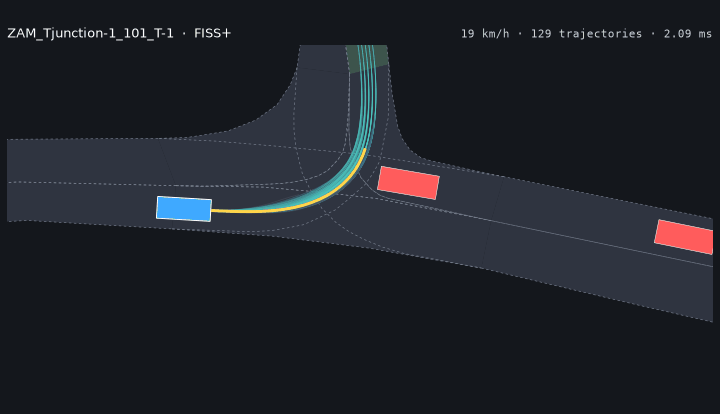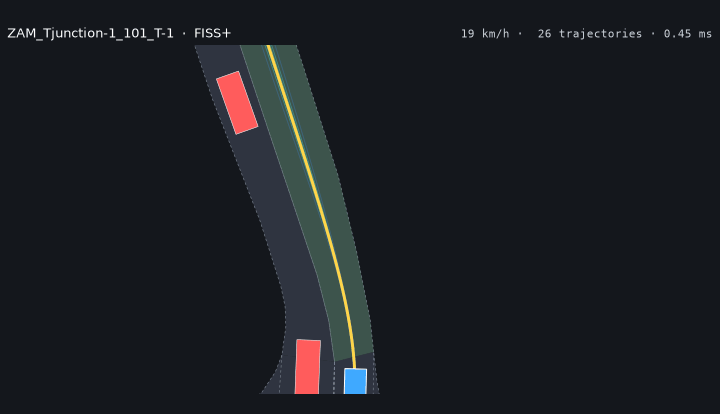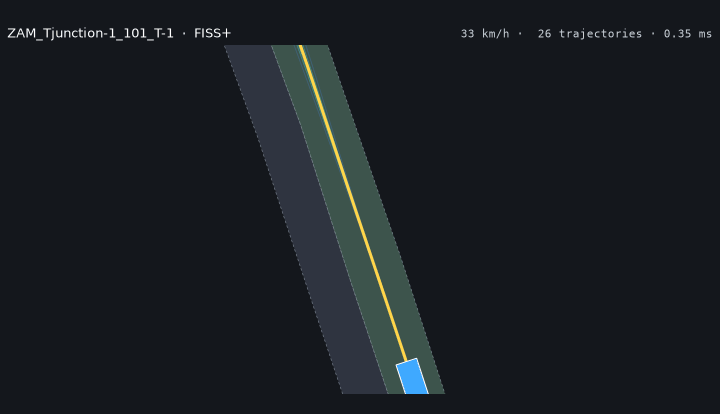
▶ Interactive replay: step through CommonRoad scenarios with every planner, including the candidate trajectories each one explored.
 |
 |
 |
 |
- Concepts: reference line, corridor, sampling, the four search strategies, validation, smoothing, stitching and control.
- Python:
pip install fiss-planner, planners,LocalPlanner, maps, controllers. - ROS: nodes, topics, parameters, Lanelet2, runtime switching.
- Benchmarks: CommonRoad, ROS 2 bag replay and CARLA results, and how to reproduce them.